Source the complete robotics hardware stack
Match edge AI, cameras, LiDAR, RF antennas, storage, displays, network hardware and I/O around the same platform requirements.
Build reliable autonomous robots with industrial hardware from Tekdis Ltd, a UK robotics hardware supplier. We support UK robotics OEMs and system integrators with NVIDIA Jetson edge AI computers, GMSL2 cameras, LiDAR, GNSS positioning, wireless connectivity, storage, power and rugged I/O for autonomous mobile robots, machine vision and industrial robotics.
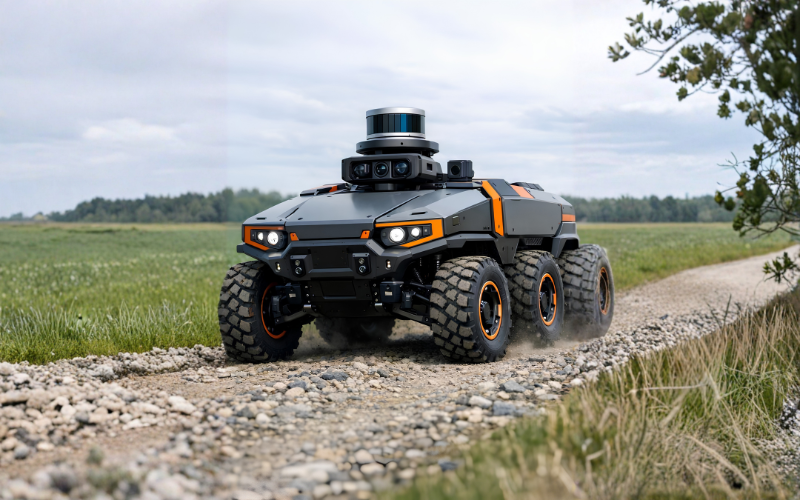
UK robotics teams often lose time sourcing cameras from one supplier, AI computers from another, LiDAR from another, and then chasing antennas, storage, displays, cables, I/O and power accessories separately. Tekdis Ltd brings the robotics hardware stack together so your engineering team can focus on the robot, not the supplier chase.
Tekdis does not supply autonomy software. We supply the hardware foundation your software runs on: edge AI computers, cameras, LiDAR, antennas, positioning hardware, network hardware, storage, displays, power and rugged I/O.
Match edge AI, cameras, LiDAR, RF antennas, storage, displays, network hardware and I/O around the same platform requirements.
Use your preferred robotics software, ROS environment, NVIDIA Isaac workflow, vision pipeline or custom application.
Support long-life supply, second-source options, replacement parts, accessory matching and scalable OEM purchasing.
Include GMSL2 cables, RF leads, mounting hardware, PoE budget, DC power, storage and wireless module options.
Your team owns the software, algorithms and robot behaviour. Tekdis supports the physical hardware layers that make the robotics platform work in the field, from prototype builds through to UK OEM production.
NVIDIA Jetson and rugged GPU systems for inference, sensor fusion and local decision-making.
GMSL2, stereo, RGB-IR and machine-vision cameras for object detection, depth and visual data.
LiDAR sensors for mapping, obstacle detection, safety zones and 3D environmental awareness.
GNSS, antennas, 4G/5G, Wi-Fi and RF accessories for positioning, telemetry and remote access.
PoE, M12, CAN bus, Ethernet, serial, DIO and expansion hardware to connect sensors and machine systems.
Industrial SSDs, memory, displays, power accessories and mounting hardware for field-ready builds.
The real value is not a single AI computer, camera or LiDAR sensor. It is the ability to supply the surrounding robotics hardware that turns those parts into a practical field-ready platform.
Tekdis can help define the hardware bill of materials for outdoor autonomous platforms, then support the supply path from sample build through to production.
Consolidate key hardware layers through one technical supply partner instead of managing a separate supplier for each subsystem.
Stronger purchasing pathConfirm interfaces, cable runs, power requirements, storage, RF and I/O before the system design becomes difficult to change.
Fewer redesign risksSelect hardware that can move from bench testing to field trials and OEM production without restarting the sourcing process.
Scalable hardware supplyAccount for vibration, temperature, dust, moisture, DC power, antenna placement, network cabling and service access.
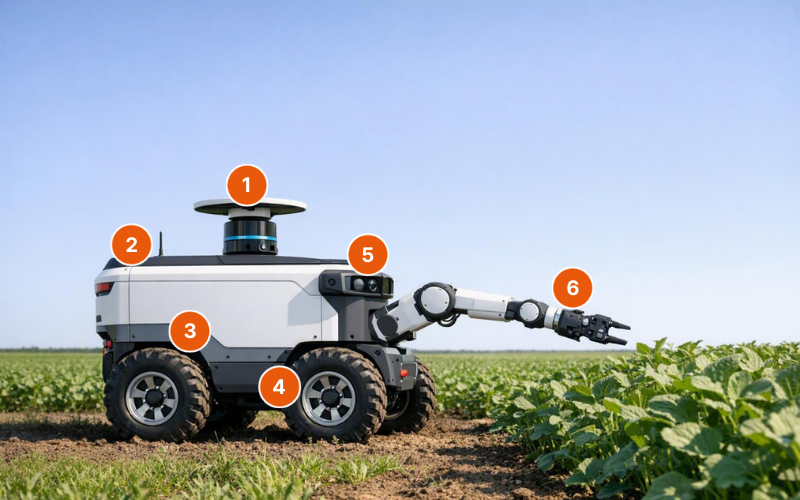
Outdoor-ready thinkingThe platform below shows how Tekdis UK hardware categories can be combined into one machine architecture, with each layer supporting sensing, navigation, edge processing, control or field connectivity.
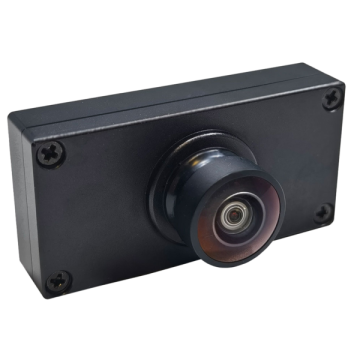
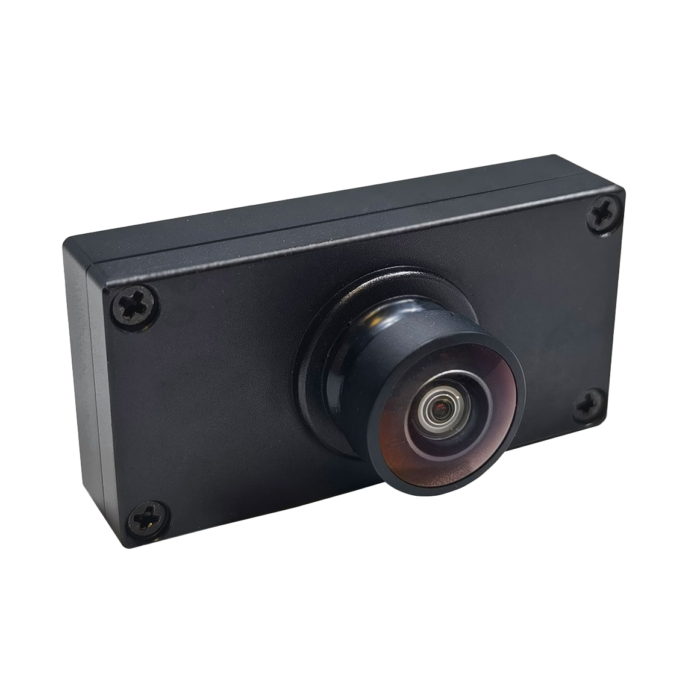 Example: Owl GMSL2 Camera
GMSL2 and stereo cameras provide low-latency visual data for object detection, crop recognition, visual SLAM and multi-camera coverage.
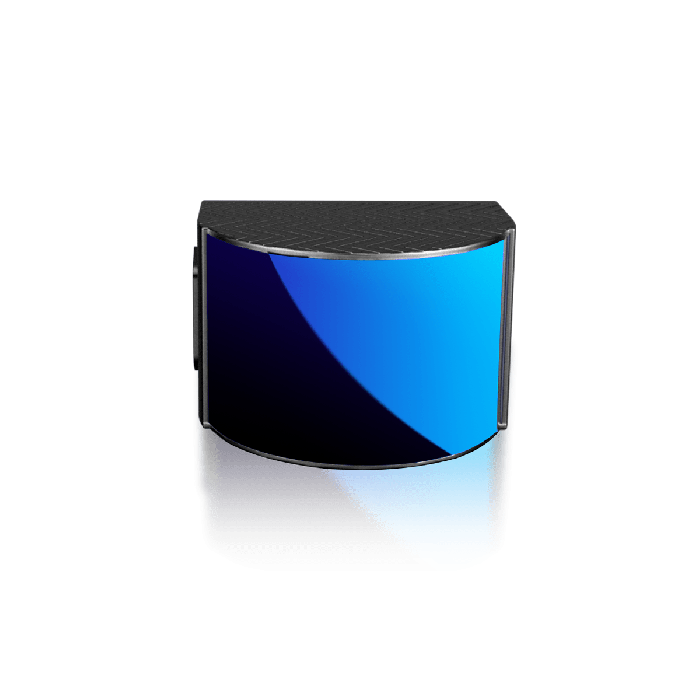 Example: CB64S1 LiDAR
LiDAR adds dense point-cloud data for mapping, near-field perception, obstacle avoidance and safety zones around the robot.
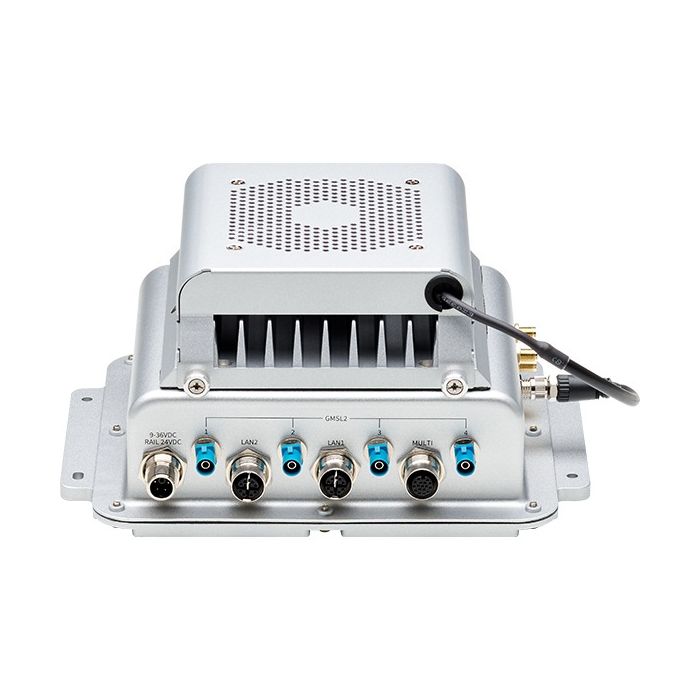 Example: ATC3562 Orin NX
The central platform provides verified GMSL2 camera input, GbE for LiDAR, optional GNSS/5G/Wi-Fi expansion, CAN bus and rugged I/O for real-time perception, fusion and control workloads.
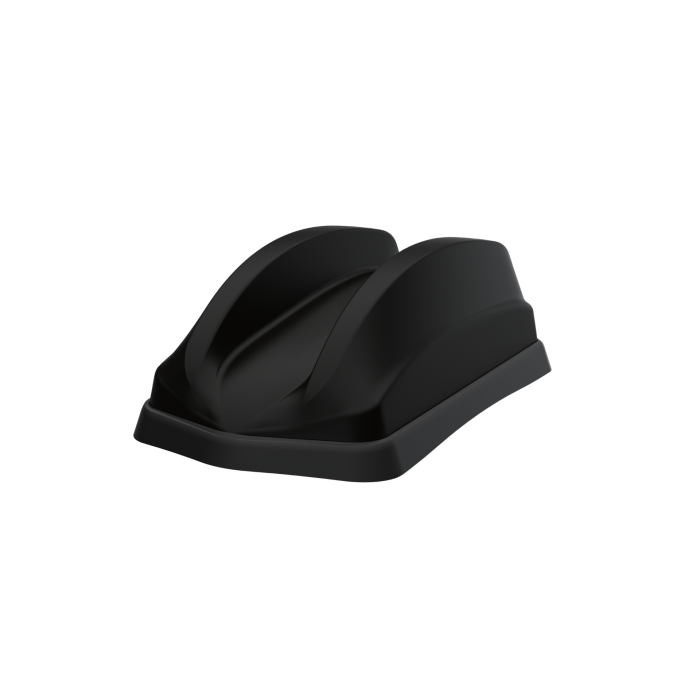 Example: 4x4 MiMo 4G/5G + WiFi, GNSS Sharkfin
A multi-function roof antenna supports cellular, Wi-Fi and GPS/GNSS signals for mobile robotics platforms. It can be paired with the edge computer’s compatible wireless and positioning module options to reduce the number of external antennas required.
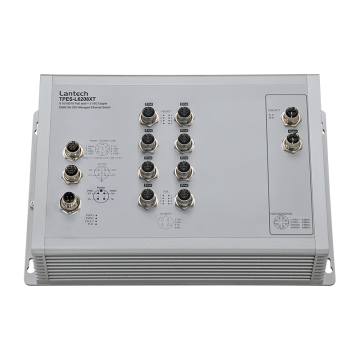
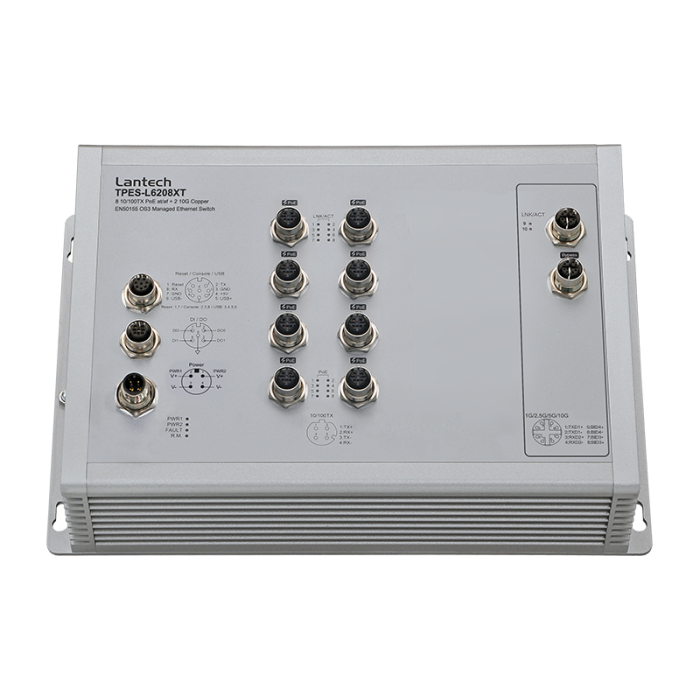 Example: T(P)ES-L6208XT PoE Switch
Used when the platform needs additional Ethernet ports, PoE power for external sensors, M12 connectivity or a rugged network point close to cameras and LiDAR. Smaller builds can connect sensors directly to the edge AI computer.
Each hardware layer answers a deployment requirement and feeds into the wider autonomous platform.
Jetson Thor or Orin systems for inference, sensor fusion, route logic and real-time control.
Depth, wide field of view, rugged camera options and GMSL2 input for multi-camera builds.
Mapping, obstacle awareness, blind-spot monitoring and ranging around the platform.
Direct sensor connections may be enough for smaller builds. Add a rugged Ethernet/PoE switch when the platform needs more ports, PoE power or distributed field cabling.
Edge AI, perception, positioning, connectivity and rugged I/O can be adapted to UK field robotics, inspection, yard automation, AMR/AGV projects and autonomous machinery.
Designed around rugged edge AI, GMSL2 vision, LiDAR, GNSS/INS and mobile connectivity.
Built around stereo depth, edge inference, object detection, robotic arm control and data logging.
Combines cameras, LiDAR, localisation and wireless networking for autonomous inspection and remote operation.
Each layer below supports a specific robotics requirement, helping UK engineering teams match the right Tekdis product groups to the platform they are building.
NVIDIA Jetson Thor and Orin systems, carrier boards and rugged GPU platforms for inference, sensor fusion, path planning and robotics workloads.
GMSL2, RGB-IR, stereo depth and machine-vision cameras for object detection, crop recognition, visual SLAM and multi-camera platforms.
360 degree, hybrid solid-state and application-specific LiDAR options for mapping, ranging, obstacle detection and safety areas.
GNSS, INS, IMU and dead-reckoning hardware for platforms that need reliable positioning around buildings, trees, tunnels or weak signal areas.
Fanless computers with wide DC input, ignition sensing, M12, PoE and CAN bus for deployment on mobile machines.
5G/LTE, Wi-Fi, PoE, M.2 modules, industrial SSDs, memory, displays and interface expansion to complete the system.
Explore example Tekdis UK hardware used across outdoor robotics, autonomous mobile robots, machine vision systems and rugged edge AI deployments.
Rugged Jetson edge AI computers for sensor fusion, perception, inference and robotics control workloads.
View example hardware Machine VisionLong-cable camera hardware for machine vision, object detection, stereo vision and autonomous platforms.
View example camera LiDAR SensorsRanging and 3D perception hardware for mapping, obstacle detection, navigation and safety zones.
View example LiDAR RF & GNSSVehicle antennas and RF hardware for positioning, telemetry, wireless connectivity and remote access.
View example antenna Rugged NetworkingRugged Ethernet and PoE expansion for cameras, LiDAR, sensor networks and distributed robotics builds.
View example switchThe products below show example hardware layers for a UK robotics build, from edge AI and perception through to ranging, external RF antennas and optional rugged network expansion.
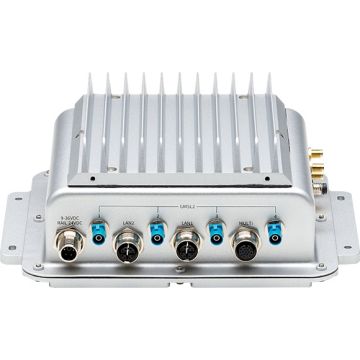
Example shown: ATC3562
The central computer provides GMSL2 input for the Owl camera, GbE for LiDAR, optional GNSS/5G/Wi-Fi expansion, CAN bus and rugged I/O for real-time perception and control workloads.
Example shown: Owl GMSL2
Camera hardware supports object detection, machine vision, crop recognition, obstacle awareness and multi-camera coverage around the platform.
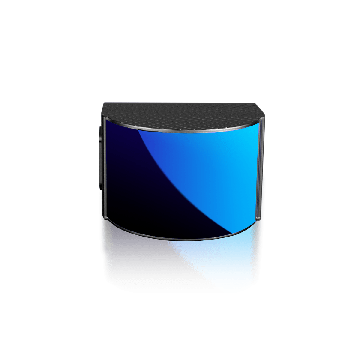
Example shown: CB64S1
LiDAR adds 3D environmental data for localisation support, near-field perception, safety zones and autonomous path planning.
Example shown: 4x4 MiMo Sharkfin
A multi-function vehicle antenna supports cellular, Wi-Fi and GPS/GNSS signals for mobile robots, reducing the need for separate antennas across the platform.
Example shown: T(P)ES-L6208XT
A rugged PoE switch can add Ethernet sensor ports, powered device support and M12 field connectivity for larger or more distributed robotics builds.
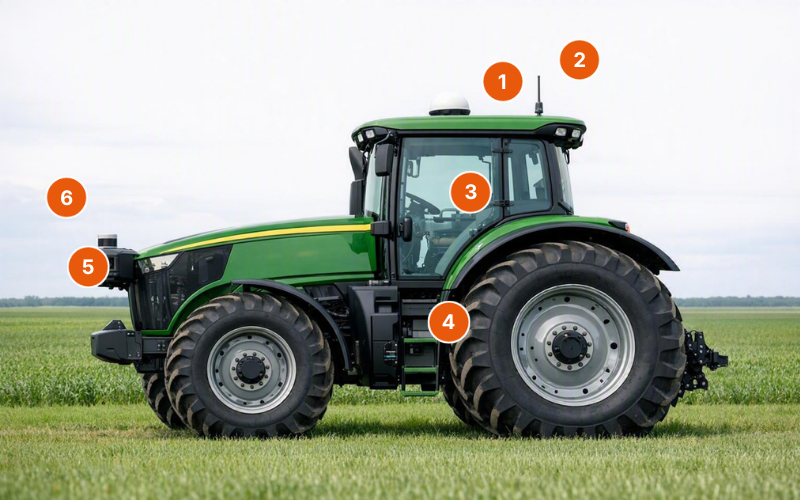
These layouts show where each robotics hardware layer can sit within a complete outdoor platform.
A rugged autonomy stack for agricultural, inspection or outdoor mobile machinery.
Runs local inference, sensor fusion, camera pipelines and route logic.
Long cable cameras provide forward, side and rear vision coverage.
3D mapping and ranging support obstacle awareness and navigation.
Positioning hardware supports localisation in open and difficult signal areas.
Remote diagnostics, telemetry, updates and fleet visibility.
CAN bus, PoE, M12, storage and power integration for deployment.
A vision-led robotics stack for detection, depth, positioning and robotic arm guidance.
Depth cameras help detect crop location, size and picking distance.
Jetson hardware runs detection models and robotic control logic locally.
LiDAR supports obstacle awareness around people, rows and structures.
CAN bus, serial and digital I/O connect the robot arm and machine systems.
5G/LTE and Wi-Fi support fleet updates, logging and remote access.
Rugged SSD and memory support image logging, datasets and system uptime.
A curated UK line-card across AI platforms, embedded PCs, sensing, vision, LiDAR and rugged robotics hardware.
The standards, interfaces and keywords UK engineers often need when specifying robotics hardware for field deployment.
Practical answers for OEMs, system integrators and engineering teams specifying hardware for autonomous robots, AMRs, AGVs, machine vision and outdoor robotics platforms.
Tekdis Ltd supplies edge AI computers, NVIDIA Jetson systems, GMSL2 cameras, stereo cameras, LiDAR, GNSS and RF antennas, rugged networking, industrial storage, memory, displays, power accessories and I/O hardware.
No. Tekdis focuses on the industrial hardware stack that supports robotics software, including hardware for ROS, NVIDIA Isaac, machine vision, sensor fusion, edge AI and custom control applications.
Yes. Tekdis can help UK OEMs and system integrators source hardware layers together, including compute, perception, ranging, positioning, wireless connectivity, storage, network hardware and rugged I/O.
Robotics perception hardware commonly includes GMSL2 cameras, 3D stereo cameras, RGB-IR cameras and LiDAR sensors connected to an edge AI computer for detection, depth, mapping and obstacle awareness.
Outdoor robots usually require rugged edge computing, IP-rated sensors, reliable power input, GNSS or inertial positioning, wireless connectivity, industrial storage, rugged cabling and interfaces such as PoE, CAN bus and M12.
Tekdis can support early samples, refresh projects, second-source options and production supply planning for UK robotics OEMs and system integrators.
Speak with the Tekdis Ltd UK team about matching AI computers, cameras, LiDAR, positioning, wireless connectivity, storage and rugged I/O for your next UK robotics project.
Build reliable autonomous robots with industrial hardware from Tekdis Ltd. We support UK robotics OEMs and system integrators with NVIDIA Jetson edge AI computers, GMSL2 cameras, LiDAR, GNSS positioning, wireless connectivity, storage, power and rugged I/O for autonomous mobile robots, machine vision and industrial robotics.
Outdoor robotics teams often lose time sourcing cameras from one supplier, AI computers from another, LiDAR from another, and then chasing antennas, storage, displays, cables, I/O and power accessories separately. Tekdis Ltd brings the hardware stack together so your engineering team can focus on the robot, not the supplier chase.
Tekdis does not supply autonomy software. We supply the hardware foundation your software runs on: edge AI computers, cameras, LiDAR, antennas, positioning hardware, network hardware, storage, displays, power and rugged I/O.
Match edge AI, cameras, LiDAR, RF antennas, storage, displays, network hardware and I/O around the same platform requirements.
Use your preferred robotics software, ROS environment, NVIDIA Isaac workflow, vision pipeline or custom application.
Support long-life supply, second-source options, replacement parts, accessory matching and scalable OEM purchasing.
Include GMSL2 cables, RF leads, mounting hardware, PoE budget, DC power, storage and wireless module options.
Your team owns the software, algorithms and robot behaviour. Tekdis supports the physical hardware layers that make the platform work in the field.
NVIDIA Jetson and rugged GPU systems for inference, sensor fusion and local decision-making.
GMSL2, stereo, RGB-IR and machine-vision cameras for object detection, depth and visual data.
LiDAR sensors for mapping, obstacle detection, safety zones and 3D environmental awareness.
GNSS, antennas, 4G/5G, Wi-Fi and RF accessories for positioning, telemetry and remote access.
PoE, M12, CAN bus, Ethernet, serial, DIO and expansion hardware to connect sensors and machine systems.
Industrial SSDs, memory, displays, power accessories and mounting hardware for field-ready builds.
The real value is not a single AI computer, camera or LiDAR sensor. It is the ability to supply the surrounding hardware that turns those parts into a practical robotics platform.
Tekdis can help define the hardware bill of materials for outdoor autonomous platforms, then support the supply path from sample build through to production.
Consolidate key hardware layers through one technical supply partner instead of managing a separate supplier for each subsystem.
Stronger purchasing pathConfirm interfaces, cable runs, power requirements, storage, RF and I/O before the system design becomes difficult to change.
Fewer redesign risksSelect hardware that can move from bench testing to field trials and OEM production without restarting the sourcing process.
Scalable hardware supplyAccount for vibration, temperature, dust, moisture, DC power, antenna placement, network cabling and service access.
Outdoor-ready thinkingThe platform below shows how Tekdis hardware categories can be combined into one machine architecture, with each layer supporting sensing, navigation, processing, control or field connectivity.
Example: Owl GMSL2 Camera
GMSL2 and stereo cameras provide low-latency visual data for object detection, crop recognition, visual SLAM and multi-camera coverage.
Example: CB64S1 LiDAR
LiDAR adds dense point-cloud data for mapping, near-field perception, obstacle avoidance and safety zones around the robot.
Example: ATC3562 Orin NX
The central platform provides verified GMSL2 camera input, GbE for LiDAR, optional GNSS/5G/Wi-Fi expansion, CAN bus and rugged I/O for real-time perception, fusion and control workloads.
Example: 4x4 MiMo 4G/5G + WiFi, GNSS Sharkfin
A multi-function roof antenna supports cellular, Wi-Fi and GPS/GNSS signals for mobile robotics platforms. It can be paired with the edge computer’s compatible wireless and positioning module options to reduce the number of external antennas required.
Example: T(P)ES-L6208XT PoE Switch
Used when the platform needs additional Ethernet ports, PoE power for external sensors, M12 connectivity or a rugged network point close to cameras and LiDAR. Smaller builds can connect sensors directly to the edge AI computer.
Each hardware layer answers a deployment requirement and feeds into the wider autonomous platform.
Jetson Thor or Orin systems for inference, sensor fusion, route logic and real-time control.
Depth, wide field of view, rugged camera options and GMSL2 input for multi-camera builds.
Mapping, obstacle awareness, blind-spot monitoring and ranging around the platform.
Direct sensor connections may be enough for smaller builds. Add a rugged Ethernet/PoE switch when the platform needs more ports, PoE power or distributed field cabling.
Edge AI, perception, positioning, connectivity and rugged I/O can be adapted to field robotics, inspection, yard automation, AMR/AGV projects and autonomous machinery.
Designed around rugged edge AI, GMSL2 vision, LiDAR, GNSS/INS and mobile connectivity.
Built around stereo depth, edge inference, object detection, robotic arm control and data logging.
Combines cameras, LiDAR, localisation and wireless networking for autonomous inspection and remote operation.
Each layer below supports a specific robotics requirement, helping engineering teams match the right Tekdis product groups to the platform they are building.
NVIDIA Jetson Thor and Orin systems, carrier boards and rugged GPU platforms for inference, sensor fusion, path planning and robotics workloads.
GMSL2, RGB-IR, stereo depth and machine-vision cameras for object detection, crop recognition, visual SLAM and multi-camera platforms.
360 degree, hybrid solid-state and application-specific LiDAR options for mapping, ranging, obstacle detection and safety areas.
GNSS, INS, IMU and dead-reckoning hardware for platforms that need reliable positioning around buildings, trees, tunnels or weak signal areas.
Fanless computers with wide DC input, ignition sensing, M12, PoE and CAN bus for deployment on mobile machines.
5G/LTE, Wi-Fi, PoE, M.2 modules, industrial SSDs, memory, displays and interface expansion to complete the system.
The products below show example hardware layers for a robotics build, from edge AI and perception through to ranging, external RF antennas and optional rugged network expansion.
Example shown: ATC3562
The central computer provides GMSL2 input for the Owl camera, GbE for LiDAR, optional GNSS/5G/Wi-Fi expansion, CAN bus and rugged I/O for real-time perception and control workloads.
Example shown: Owl GMSL2
Camera hardware supports object detection, machine vision, crop recognition, obstacle awareness and multi-camera coverage around the platform.
Example shown: CB64S1
LiDAR adds 3D environmental data for localisation support, near-field perception, safety zones and autonomous path planning.
Example shown: 4x4 MiMo Sharkfin
A multi-function vehicle antenna supports cellular, Wi-Fi and GPS/GNSS signals for mobile robots, reducing the need for separate antennas across the platform.
Example shown: T(P)ES-L6208XT
A rugged PoE switch can add Ethernet sensor ports, powered device support and M12 field connectivity for larger or more distributed robotics builds.
These layouts show where each hardware layer can sit within a complete robotics platform.
A rugged autonomy stack for agricultural, inspection or outdoor mobile machinery.
Runs local inference, sensor fusion, camera pipelines and route logic.
Long cable cameras provide forward, side and rear vision coverage.
3D mapping and ranging support obstacle awareness and navigation.
Positioning hardware supports localisation in open and difficult signal areas.
Remote diagnostics, telemetry, updates and fleet visibility.
CAN bus, PoE, M12, storage and power integration for deployment.
A vision-led robotics stack for detection, depth, positioning and robotic arm guidance.
Depth cameras help detect crop location, size and picking distance.
Jetson hardware runs detection models and robotic control logic locally.
LiDAR supports obstacle awareness around people, rows and structures.
CAN bus, serial and digital I/O connect the robot arm and machine systems.
5G/LTE and Wi-Fi support fleet updates, logging and remote access.
Rugged SSD and memory support image logging, datasets and system uptime.
A curated line-card across AI platforms, embedded PCs, sensing, vision, LiDAR and rugged robotics hardware.
The standards, interfaces and keywords engineers often need when specifying robotics hardware for field deployment.
Speak with the Tekdis Ltd UK team about matching AI computers, cameras, LiDAR, positioning, wireless connectivity, storage and rugged I/O for your next robotics project.